
Products
Solutions
Technical Information
Motor Sizing
Downloads
Contact Us
Industrial Robots > Technology > SCARA Robots Motor Assembly Demo Case Study
Case Study - SCARA Robots Motor Assembly Demo
For this case study, our application engineering group combined 2 OVR Series SCARA robots and MRCU robot controllers with EZS & KR Linear Slides and EH Series Electric Grippers for end effectors to demonstrate picking and placing coordination in a tight workspace assembling a stepper motor.
- Intro
- Area Outputs
- Low Profile SCARA
- Full 360° SCARA
- Z-Axis
- Tool Offset
- Electric Gripper
- MRC Software
- Support
Tool Offset
Changing Tool Offset Command
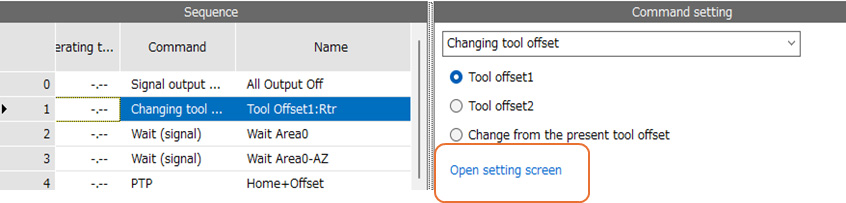
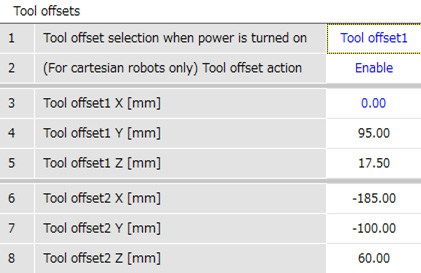
The MRC controller allows 2 Tool-Offset settings of TCP can be set to program different shape or position being used.
In this demo, the TCP position is switched between the Electrical gripper and the Pneumatical suction cap.
In this demonstration, OVR3041K3-H uses two end effectors, EH electrical gripper and CKD puematic suction cup.
The EH electrical gripper handle the rotors and the pneumatic suction cup handles the stators.
Changing tool offset: This is a command to switch the tool offset. Two offset values of TCP can be set to the controller according to the shape of the tool being used. When using two tools with different shapes, TCP can be switched according to the tool being controlled.
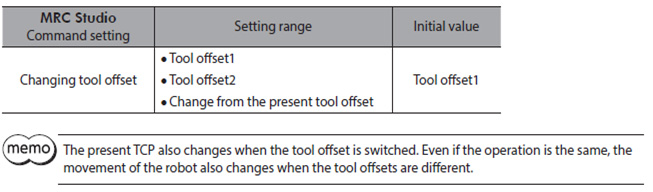
MRC Studio Command Setting
MRC Studio Tool Offset Parameter Setting
Learn More About The Products Used
OVR Series SCARA Robots
|
MRCU Integrated Robot Controller & Drivers
|
MRC Studio Robot Software
|
EH Series Gripper
|
EZS Series Linear Slides
|
AZ Series Step-Servo Motors
|
THK Linear Slides
|
|




We're Here to Help

On Demand Webinar

Industrial Robots


