
Products
Solutions
Technical Information
Motor Sizing
Downloads
Contact Us
Industrial Robots > Technology > SCARA Robots Motor Assembly Demo Case Study
Case Study - SCARA Robots Motor Assembly Demo
For this case study, our application engineering group combined 2 OVR Series SCARA robots and MRCU robot controllers with EZS & KR Linear Slides and EH Series Electric Grippers for end effectors to demonstrate picking and placing coordination in a tight workspace assembling a stepper motor.
- Intro
- Area Outputs
- Low Profile SCARA
- Full 360° SCARA
- Z-Axis
- Tool Offset
- Electric Gripper
- MRC Software
- Support
Introduction
Motor Assembly Automation
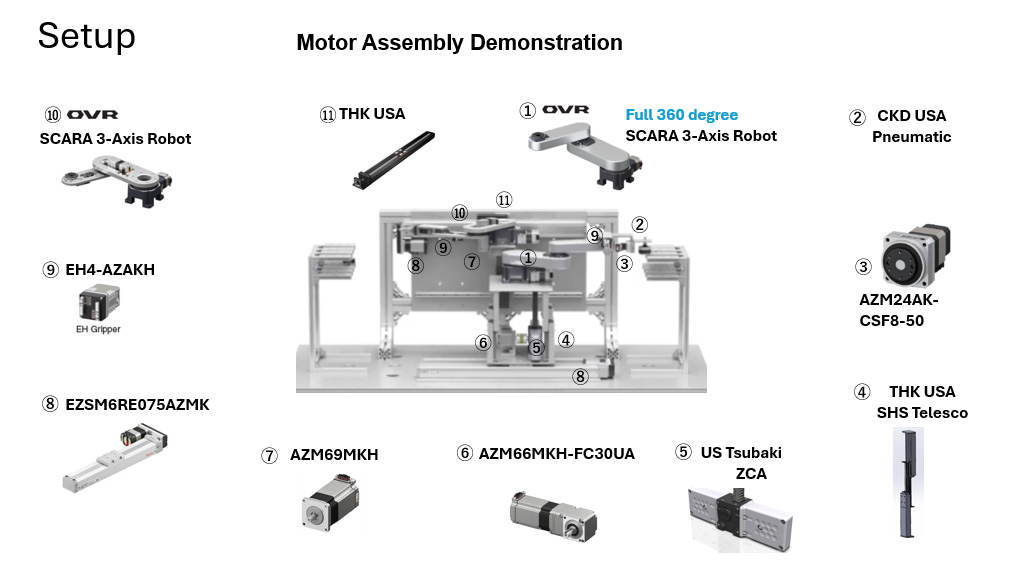
The material handling demo consists of two OVR SCARA Robots; one low profile 3-axis SCARA robot with a reach of 410mm and one Full 360° SCARA robot with a reach of 460mm.
Robot 1 - Low Profile SCARA Robot
The standard SCARA utilizes utilizes an electric gripper to handle the motor flange assembly and motor alignment due to limited vertical clearance.
Vertical positining (Z-axis) is handled using a THK Linear Slide and AZ Series stepper motors.
Robot 2 - Full 360° SCARA Robot
The Full 360° SCARA two offset end effectors; an electric gripper and a pneumatic suction cup.
The electric gripper handles the rotors for motor assembly and the pneumatic suction cup handles the stators.
Vertical positioning (Z-axis) is done via a telescoping table driven by a Tsubaki Zip Chain Actuator (ZCA) and AZ Series stepper motor with THK USA SHS Telescopic Rails which allow for smooth and highly accurate positioning.
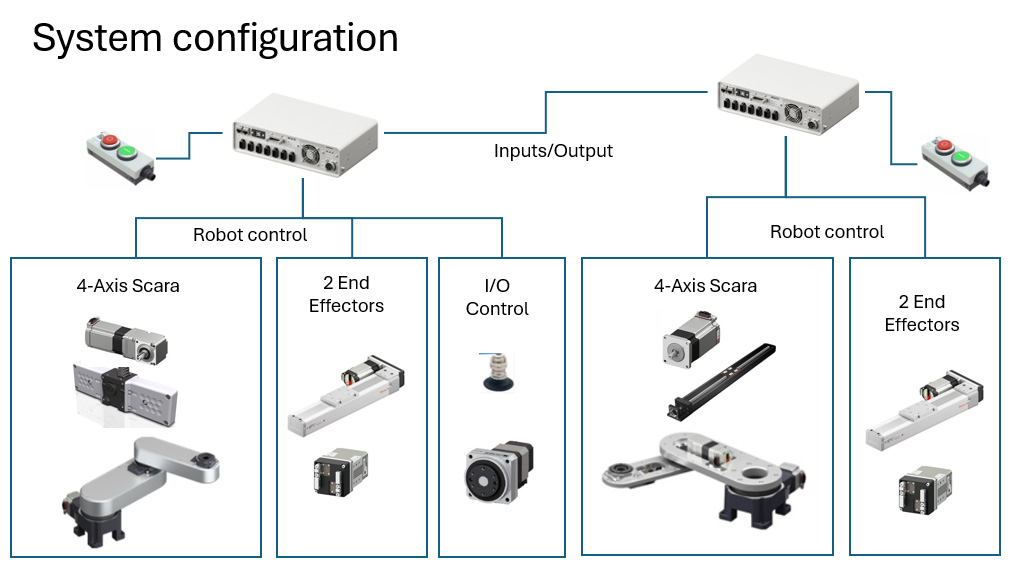
The two robots and Z-axis are controlled using MRCU robot controllers.
System Configuration
Learn More About The Products Used
OVR Series SCARA Robots
|
MRCU Integrated Robot Controller & Drivers
|
MRC Studio Robot Software
|
EH Series Gripper
|
EZS Series Linear Slides
|
AZ Series Step-Servo Motors
|
THK Linear Slides
|
|




We're Here to Help

On Demand Webinar

Industrial Robots


